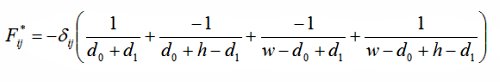Saturday, October 6, 2012

Generalized Relational Perspective Map

This post describes a variation of the algorithm Relational Perspective Map (RPM)[1]. The new algorithm, called generalized RPM (gRPM), is more sound from the view point of simulated dynamical system; and produces in general more consistent maps. gRPM has been implemented in VisuMap and has been available since version 2.4. In the following I'll first review the RPM algorithm; then describe gRPM for a special case that employs flat torus topology; I'll then discuss possible variation and extension of the algorithm.

As a MDS (multidimensional scaling) algorithm, RPM seeks to map a set of data points from high dimensional space to the surface of a torus, so that the following "Energy" is minimal:
where δij  is the distance matrix between the data points in the high dimensional space; and dij  is the distance matrix for the data points on the torus. RPM uses the gradient-descent algorithm to minimize the energy E, so that RPM in effect simulates a multi-particle system to find a minimal energy configuration on the torus directed by the following "force":
The negative sign in above formula indicates that the "particles" exert repulsive force on each other;  and the closer two "particles" are on the torus, the larger is the repulsive force. The following picture illustrates the RPM algorithm:

Figure 1: RPM as a mapping algorithm.

In the initial RMP paper, the distance dij is defined as the minimal geodesic distance on the torus surface. This definition leads to a problem that, when two particles are located close to the opposite sites of the torus, the repulsive force between them becomes unstable with alternating directions. The following diagram illustrates this case (where I made the thickness of the torus infinitely small so that the torus becomes in effect a ring):
Figure 2: RPM dynamics anomaly on a ring: the force from A to B+ and B_ have different direction even B+ and B_ can be arbitrarily close to B.

In above diagram, the repulsive force between  A and B can quickly change the direction when the particle B moves from position B_ to B+, because the repulsive force follows the minimal path that changed from upper half arc to lower half arc. As will be shown latter, this kind of discontinuity can lead to unwanted artifacts in the resulting RPM maps.

In order to fix the discontinuity problem described above, the gRPM algorithm extends the interaction between two particles to multiple paths between them. In the case of ring topology, gRPM defines the interaction between two particles as superposition of two forces: one along the upper arc and one along the lower arc in above picture. By this definition, when two particles are at exact opposite positions, A and B, on the ring, the two paths between them (i.e. the two arcs) will have equal length, so that the two forces will have equal absolute value but opposite direction. Thus, the two forces will cancel out each other; and the two particles can stay stably at the position A and B.

Formally, let's represent the ring by the numbers in the interval [0, w], where w is the length of the ring;  let i and j be two data points mapped to the position x  and y  in [0, w]. With this representation the two ending points at 0 and w, as shown in the following picture, should be considered as stuck together:


Figure 3: Interval representation of a ring topology.


Then the force between i and j according RPM will be:


The energy and force between i and j according gRPM will be:


We can easily verify that Fij, as a function of x and y, is not continues when |x-y|=w/2. But, F*ij is continues and has the value 0 when |x-y|=w/2.

For two dimensional torus, there will be 4 different paths connecting any two different points on the torus surface. The  four paths are illustrated in the following picture:
Figure 4: Four paths between two points on a flat torus. Opposite edge of the rectangle should be consided stuck together.

Let (x0, x1) and (y0, y1) be the coordinate of two data points i and j, d0:=|x0-y0|,  d1:=|x1-y1|; then the energy and force between the two points are:

The consts w and h  in above equation are the width and length of the flat torus respectively.

To compare gRPM with RPM we have applied both algorithms to the sphere data set. The following pictures show the result:


Figure 5: Mapping 1000 data points sampled from a sphere surface to the flat torus: a) The original dataset displayed as scatter plot in the 3D sphace. b) The map generated by the RPM algorithm. c) The map generated by the gRPM algorithm.

We notice that there is kind of framing effect in the map generated by RPM algorithm: high concentration of data points along the boundary of the two square fragments. The map generated by gRPM does not suffer from such framing effect.

The key technique to move RPM to gRPM is to find a set of  "conjugated" paths, so the forces induced by them will cancel each out at those "discontinuous" configurations of RPM. With this technique we have worked out gRPM algorithm for other relatively simple spaces (e.g. 2D smooth manifolds). In VisuMap we have implemented gRPM for flat klein-bottle, flat sphere, flat real projective plane (all flat fundamental polygons), 3D sphere and the projective plane in half-sphere model. The set of conjugated paths for these manifolds comprise 2 to 8 paths.

Discussions:

  • The initial RPM algorithm defines the energy as 1/dpij, where p is any positive number. Just for the sake of simplicity, we have here just considered the case p=0. The handling of other values for p should be analogous. In fact,  for any smooth monotonously increasing function h(x), we can use the function 1/h( dij) as energy function for gRPM.

  • Notice that, for the ring topology, the two "conjugated" paths form a complete winding loop (see Figure 1.) As an extension, we could require that the path pair forms two winding loops. As shown in the following diagram, two particles will have minimal energy when they are at the same spot (that is the same phase but different loop). Thus, the repulsive force will be effectively turned into attractive force.

    In general, we can easily verify that, for the ring topology, the interaction is repulsive when the path pair forms odd number of loops; and is attractive when the path pair forms even number of loops. This kind of winding number resemble the spin numbers of bosons and fermions in particle physics. It might be interesting to investigate gRPM for these more general cases.

  1. Visualization of high-dimensional data with relational perspective map, James X. Li, Information Visualization 2004; 3, 49-59.

Monday, September 17, 2012

Data Visualization on Dual Monitor Systems

I have just uploaded a short video to youtube that demonstrates the capability of VisuMap
to visualize large dataset on a dual monitor system. It is the first time that I used a HD
carmcorder to make videos for YouTube. It was a challenge to squeeze the large screen HD pixels to youtube sized videos, I hope the video shows at least some interactive perspectives of the software product.

Wednesday, August 29, 2012

On Gauge Principal Component Analysis

Principal Component Analysis (PCA) is a widely used method to investigate high dimensional data. Basically, PCA, as a dimensionality reduction method, rotates a data set in the high dimensional space so that it shows most information (i.e. variance) from certain view direction. In this note, I am going to describe a very simple yet effective extension of PCA. The method, which I call Guage PCA  (GPCA), works as follows: Instead a of using a single global rotation as in normal PCA,  GPCA first decomposes the dataset into multiple clusters, then find a rotation for each clusters; and then compose a global map from the rotated clusters. The following picture illustrates the steps of GPCA:


We can image that above maps illustrate the scenario to take snapshot of a fish tank with 4 different fishes.  The top map is a random snapshot in which the fishes face different directions. The middle section  are the 4 fishes rotated to show maximal information to the viewer. The last map is a snapshot of the fish tank with all fishes magically rotated, so that each fish shows the maximal information to the viewer. This scenario is sort of an extension of the scenario described in the video "A layman's introduction to principal component analysis".

In certain sense, the relationship of PCA to GPCA is analogous to the relationship between linear regression and linear spline: the former uses a single straight line to approximate a curve, whereas the latter uses multiple line segments. It is obvious that linear spline, as approximation method, is much more powerful than linear regression. The following picture illustrates how linear regression and linear spline approximate a set of points:


A key requirement for linear spline is that the line segments have to be joined together to form a single polyline. Similarly for GPCA, we require that the composed resulting map to preserve variance of the map in major directions. It should be noticed that there are many PCA related approaches under the term localized PCA. Those approaches mostly focus on how to segment the data, but ignore the step to compose a single global map for visualization purpose. In contrast, the composition step in GPCA is the key step. The creation of the initial map and the segmentation of the data is actually not part of the algorithm but just initial conditions.

VisuMap has been supporting GPCA for a while now. In order to use GPCA, we first create a MDS map and cluster the data with any available clustering algorithm of VisuMap; then open the PCA view for a selected cluster and click on the capture button to embed the local PCA map back into to original MDS map. The following video shows the process to create GPCA map for a sample dataset from pharmaceutics :


I have borrowed the term gauge from modern physics in which the gauge principle plays a fundamental role. The gauge principle states that a global system behavior is invariant under local gauge rotation. So for instance, when we calculate orbits of planets in our solar system we don't have to care about the orientation of individual planets. The orientation of planets is  an additional freedom that has no impact on structure of orbits. This kind of extra degree of freedom has turned out to be the core structure underlying many laws in modern physics.


Thursday, August 23, 2012

Tracking Attributes in a MDS map.

When using MDS (multidimensional scaling) maps in the practice, a frequently asked question is how does a particular attribute, i.e. a data column in the input table, impact the resulting MDS map? One simple way to visualize the effect of an attribute is just create another MDS map without that attribute under investigation. The  difference between the two maps can be then ascribed to that attribute. For instance, the following two maps are MDS maps (created with CCA aglrotihm) of the VisuMap sample dataset yeast.xvm: the fisrt is created with the first 5 attributes; second one with just the first 4 attributes.


The difference between the two maps above is thus caused by leaving out the fifth attribute (i.e. the attribute spo2). We notice that the two major data point clusters (colored as yellow and cyan)  are more separated in the first map. Thus, we can see that the attribute spo2 provides significant separation for these two clusters.

With the VisuMap plugin module ClipRecorder we can do a much better job to visualize the effect of a attribute. The newly released ClipRecorder version 1.2 includes scripts that help users to create a sequence of MDS maps with gradually decreasing weight for a selected attributes.  The difference between two successive maps provides direction vectors which indicate how data points move when the weight for the selected attributes decreases. The following map is one of such map that visualizes the movement direction of all data points at certain moment during the running process of the script:


In above map, each bi-colored bar represents a data point; the red side of the bar points to the moving direction of a data point and the length of the bar indicates the speed of the movement.

The ClipRecorder plugin also records all the map sequences, so that we can replay them any time later as simple map animation. The following short video clip, for instance, shows such an animation: